Filter cuboids below point threshold
1 min
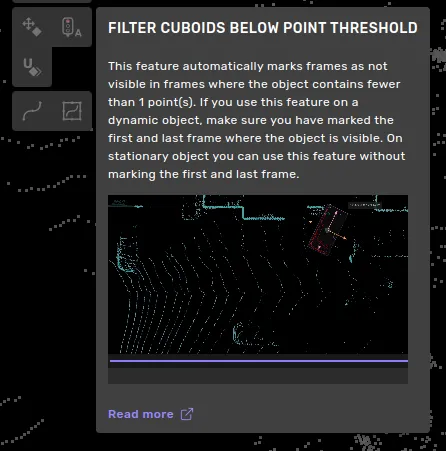
Using this feature will mark all frames as not visible if the number of points inside the cuboid is below the configured threshold.
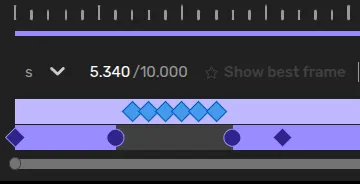
The process of using this feature is different depending on whether the object is considered stationary or dynamic. It is described in the chapters below.